C++ MIT

lidar_inertial_odometry

Tightly-Coupled Lidar-Inertial Odometry

9

93won

Dernière activité 8 sept. 2026
93won/lidar_inertial_odometry

218

étoiles

26

forks

3

issues ouvertes

Ce README est souvent en anglais.

Tightly-Coupled LiDAR-Inertial Odometry

MIT Licence

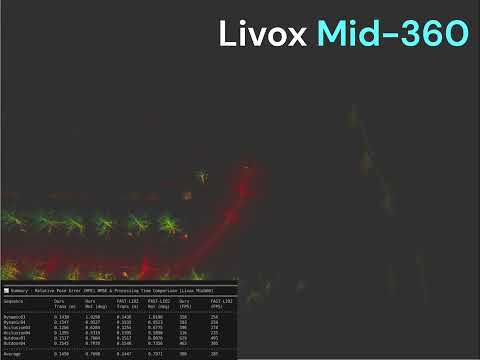
Demo

LIO Demo

Quick Start

Installation and dataset guide

ROS 2 Wrapper

lio_ros_wrapper — requires updates for the v0.1.0 core.

Release Notes

References

@misc{choi2025surfellio,
  title={Surfel-LIO: Fast LiDAR-Inertial Odometry with Pre-computed Surfels and Hierarchical Z-order Voxel Hashing},
  author={Seungwon Choi and Dong-Gyu Park and Seo-Yeon Hwang and Tae-Wan Kim},
  year={2025},
  eprint={2512.03397},
  archivePrefix={arXiv},
  primaryClass={cs.RO},
  url={https://arxiv.org/abs/2512.03397}
}
@article{choi2025pko,
  title={Probabilistic Kernel Optimization for Robust State Estimation},
  author={Choi, Seungwon and Kim, Tae-Wan},
  journal={IEEE Robotics and Automation Letters},
  volume={10},
  number={3},
  pages={2998--3005},
  year={2025},
  publisher={IEEE}
}

Projets similaires

iG-LIO: An Incremental GICP-based Tightly-coupled LiDAR-inertial Odometry

C++
Zzijiechenrobotics
523 étoiles71

Faster-LIO: Lightweight Tightly Coupled Lidar-inertial Odometry using Parallel Sparse Incremental Voxels

C++
Ggaoxiang12
1,6 k étoiles362

Visual-Inertial Odometry using 360 Camera

C++
993won
181 étoiles21