A lightweight, YAML-driven robot simulator for navigation, control, and learning





IR-SIM is an open-source, Python-based, lightweight robot simulator designed for navigation, control, and learning. It provides a simple, user-friendly framework with built-in collision detection for modeling robots, sensors, and environments. Ideal for academic and educational use, IR-SIM enables rapid prototyping of robotics and learning algorithms in custom scenarios with minimal coding and hardware requirements.
- Simulate robot platforms with diverse kinematics, sensors, and behaviors (support).
- Quickly configure and customize scenarios using straightforward YAML files. No complex coding required.
- Visualize simulation results with a lightweight Matplotlib-based renderer for rapid debugging.
- Support collision detection and customizable behavior policies for each object.
- Suitable for multi-agent and robot-learning research (Projects).
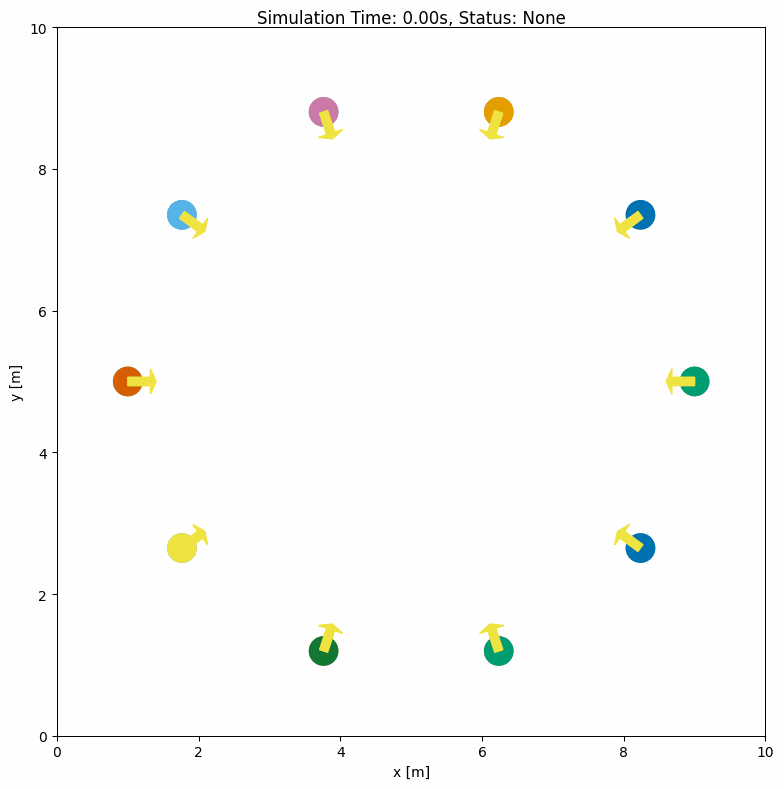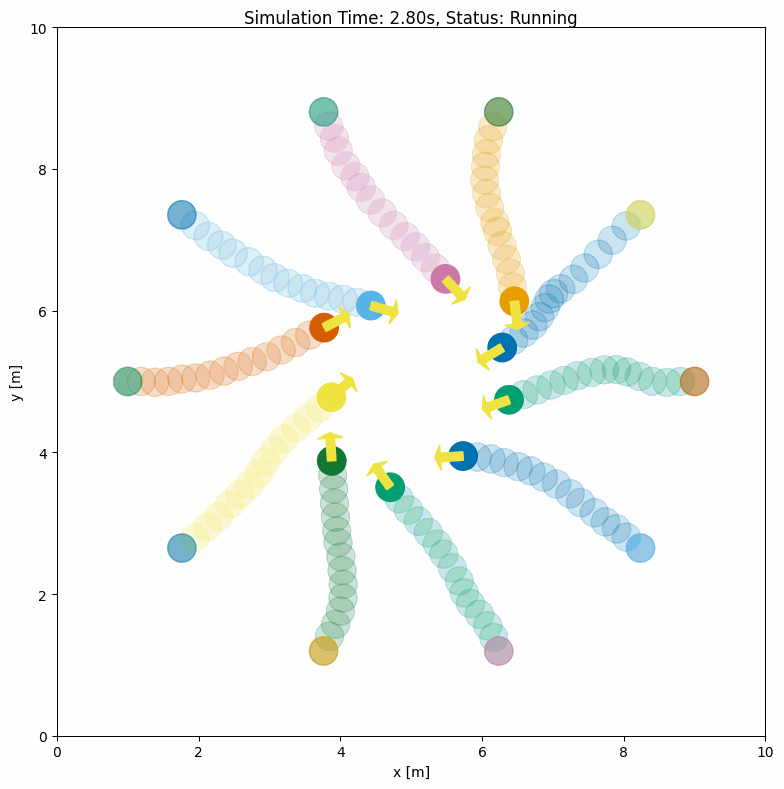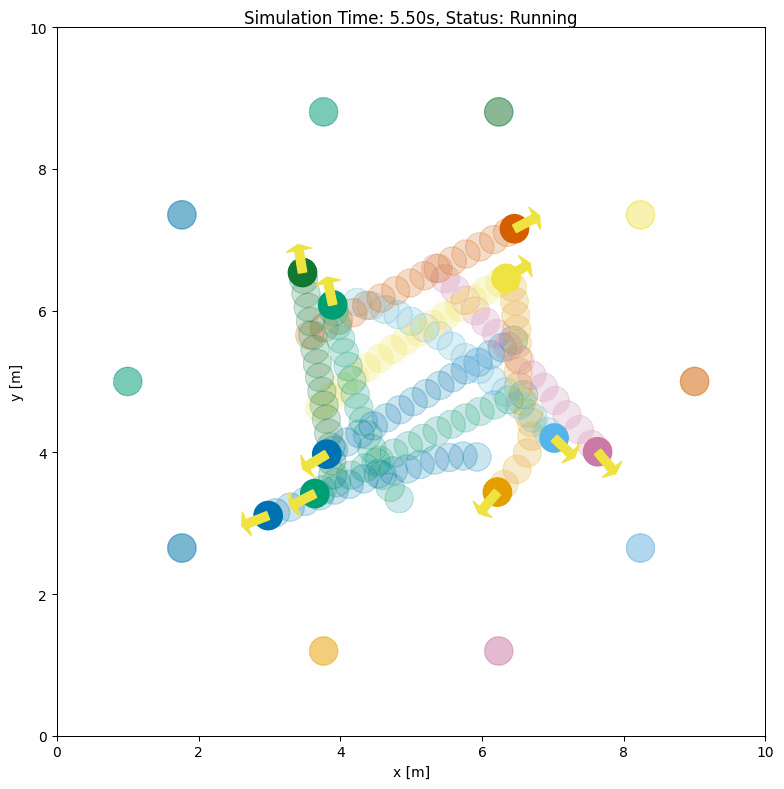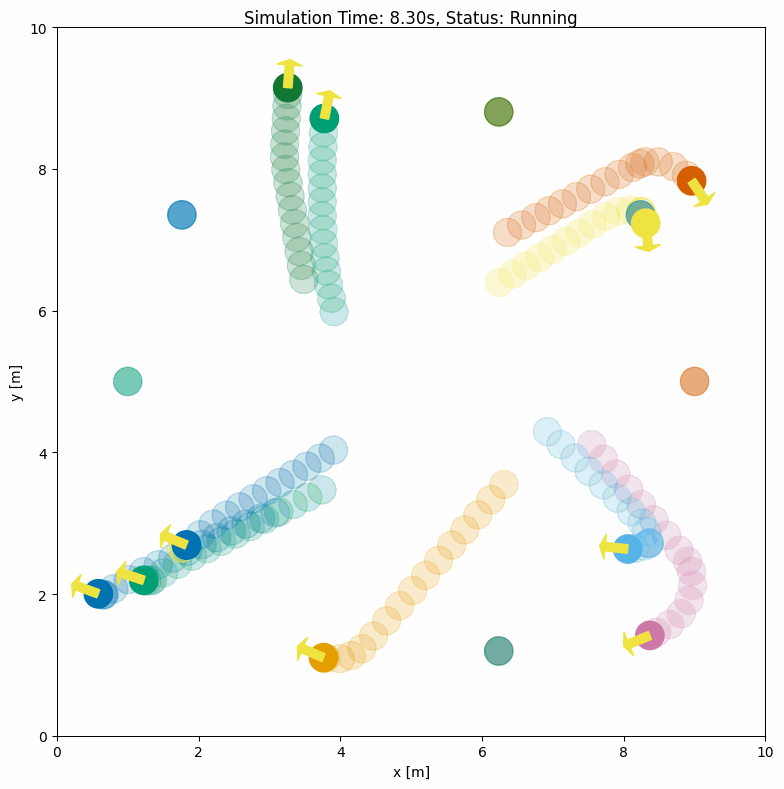 Multi-Robot RVO Collision Avoidance Source |
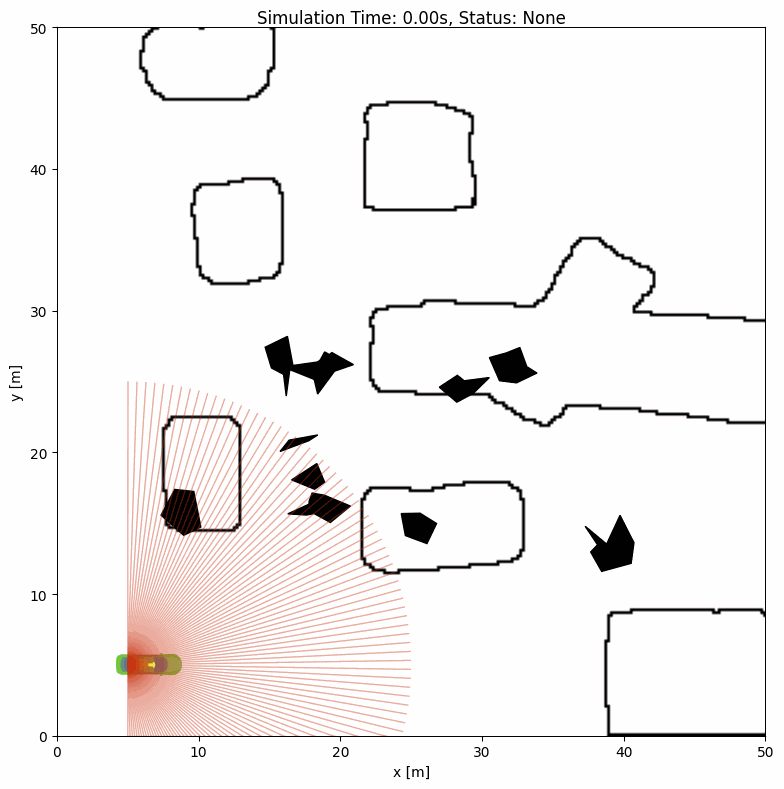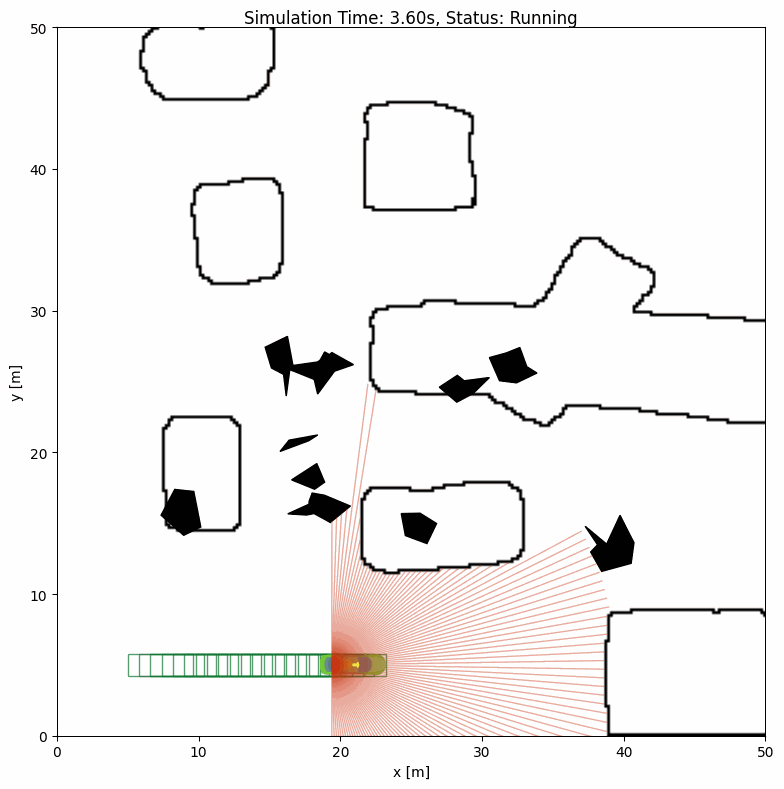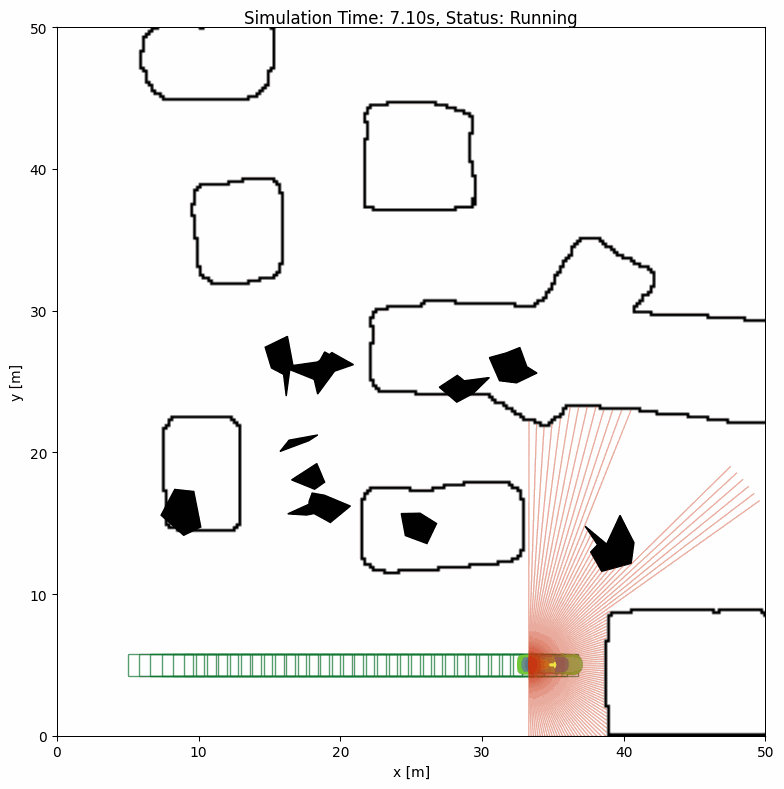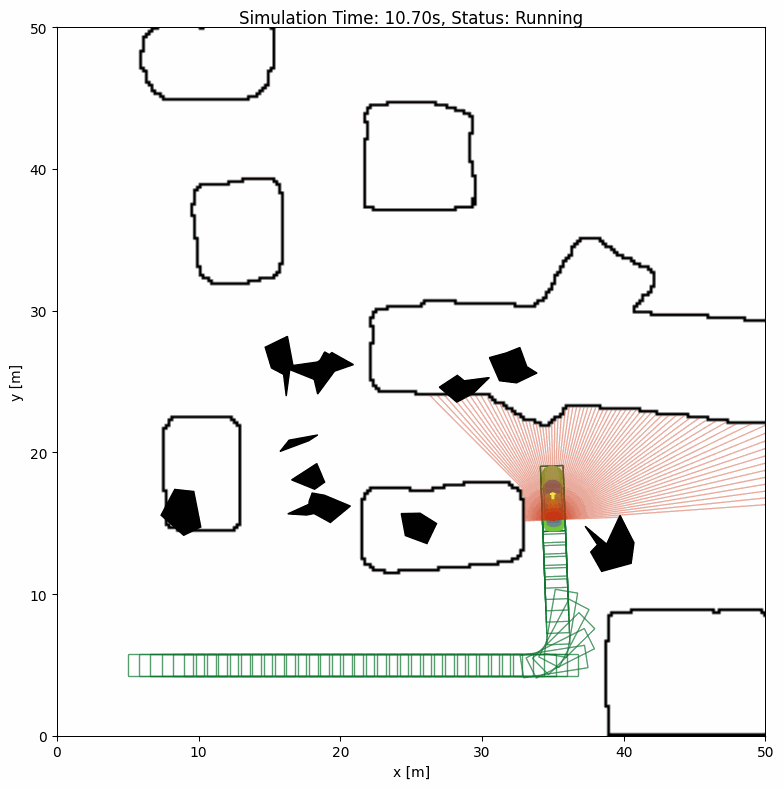 Ackermann Robot with 2D LiDAR Source |
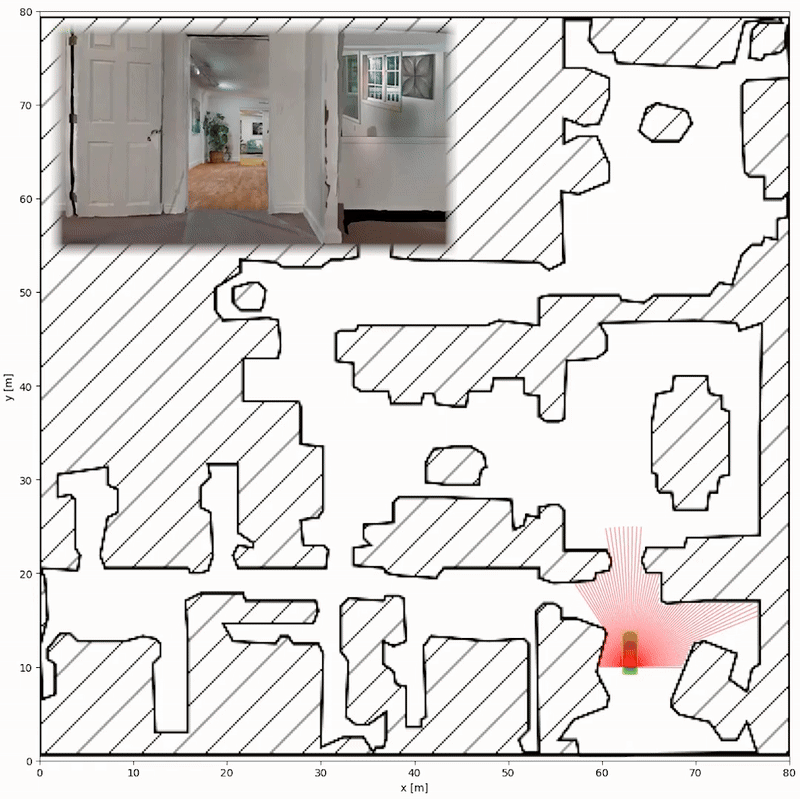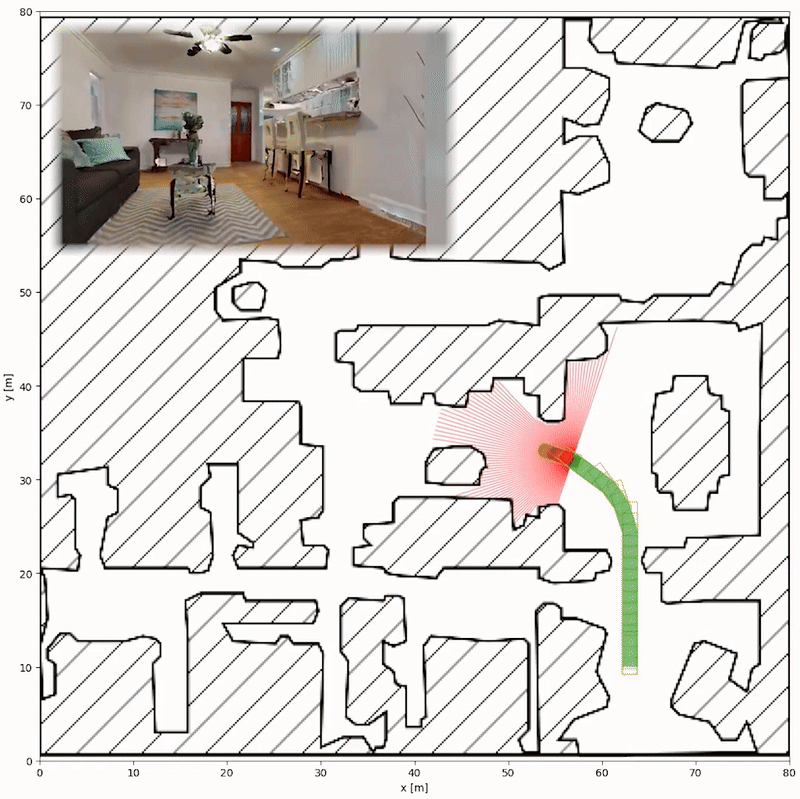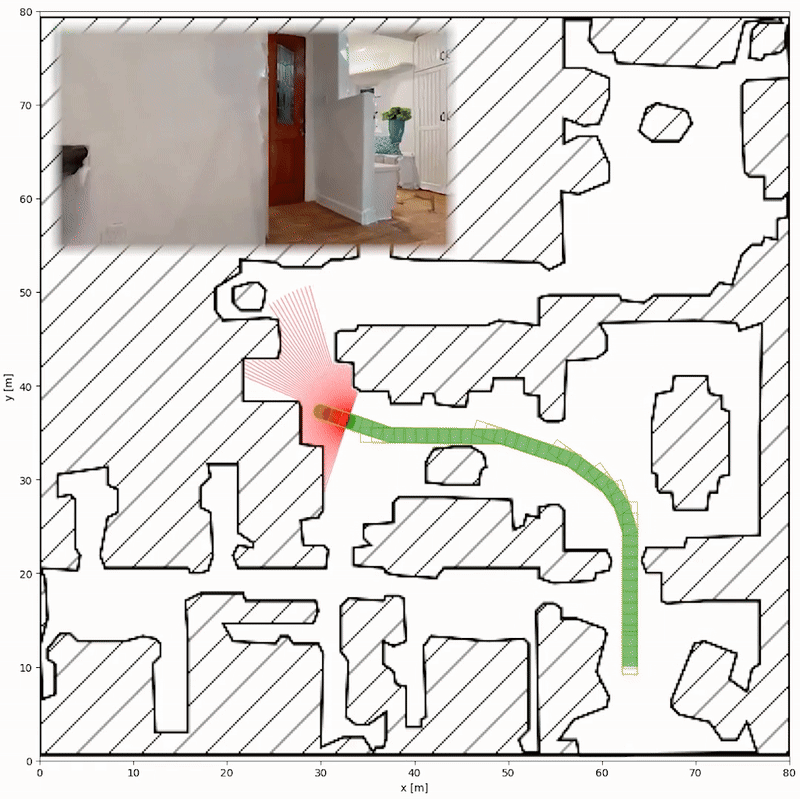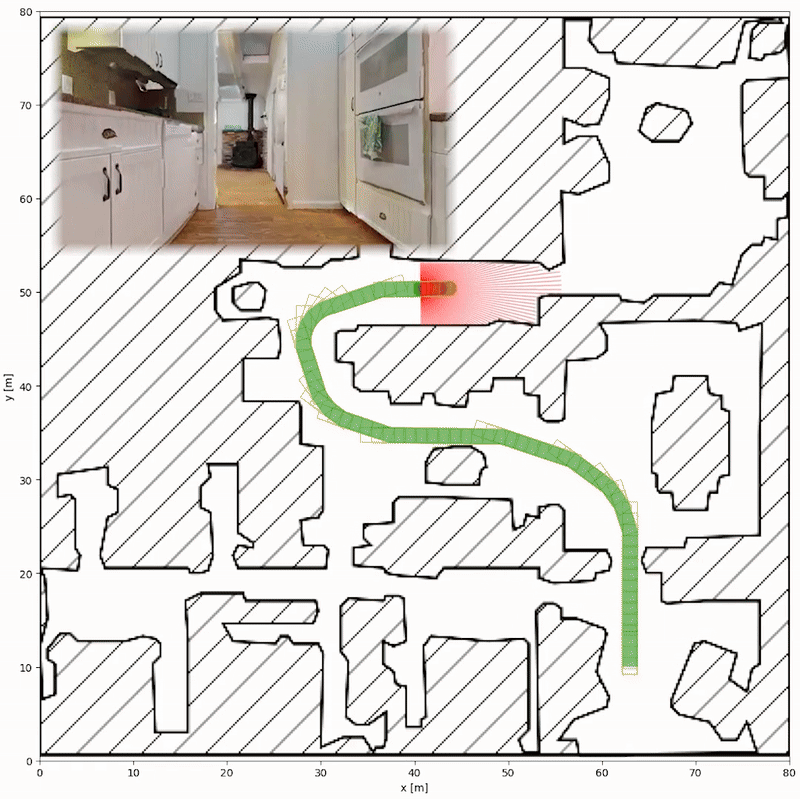 HM3D / MatterPort3D Grid Map Source |
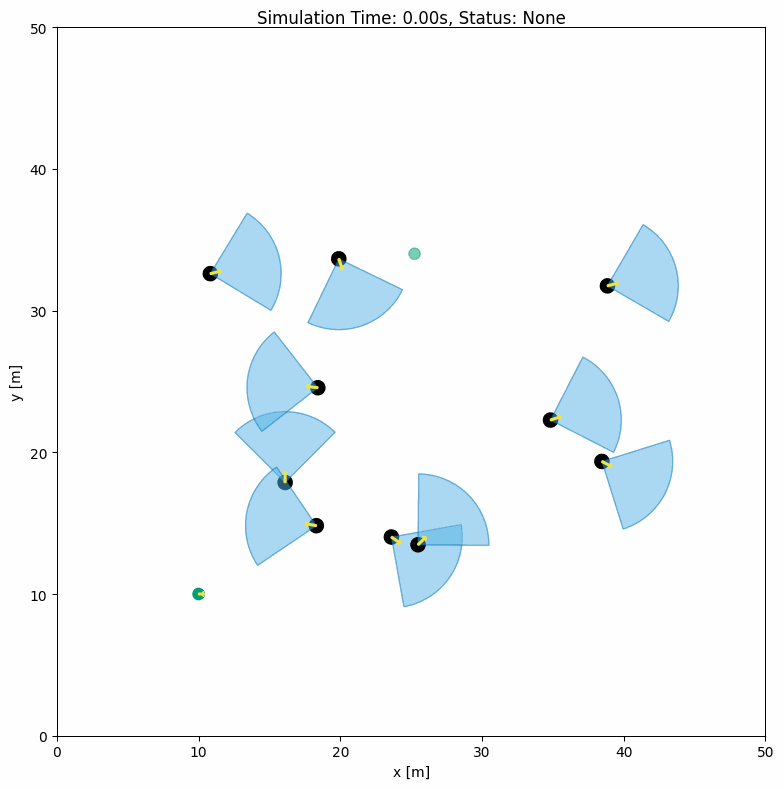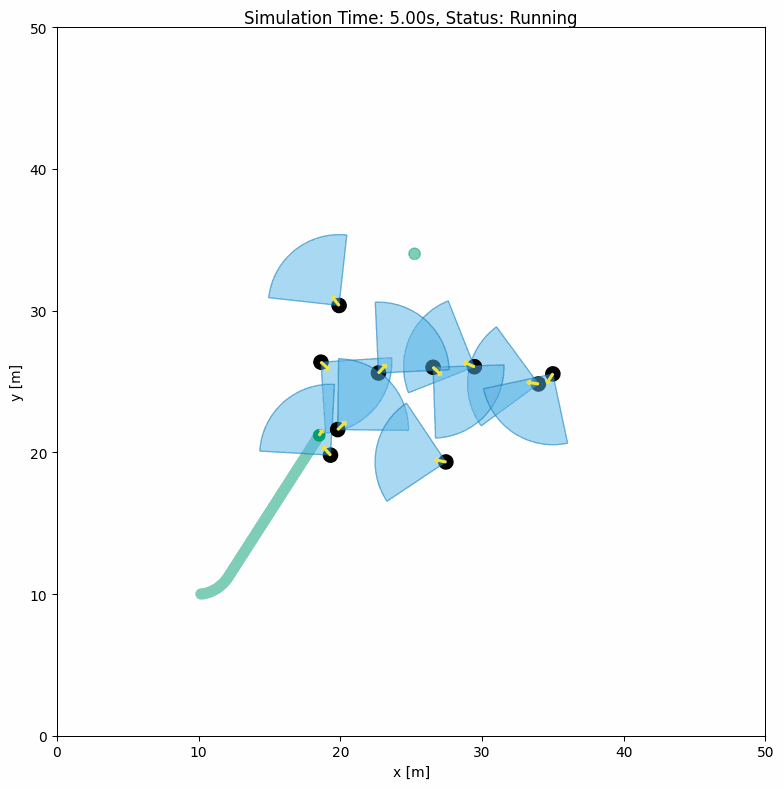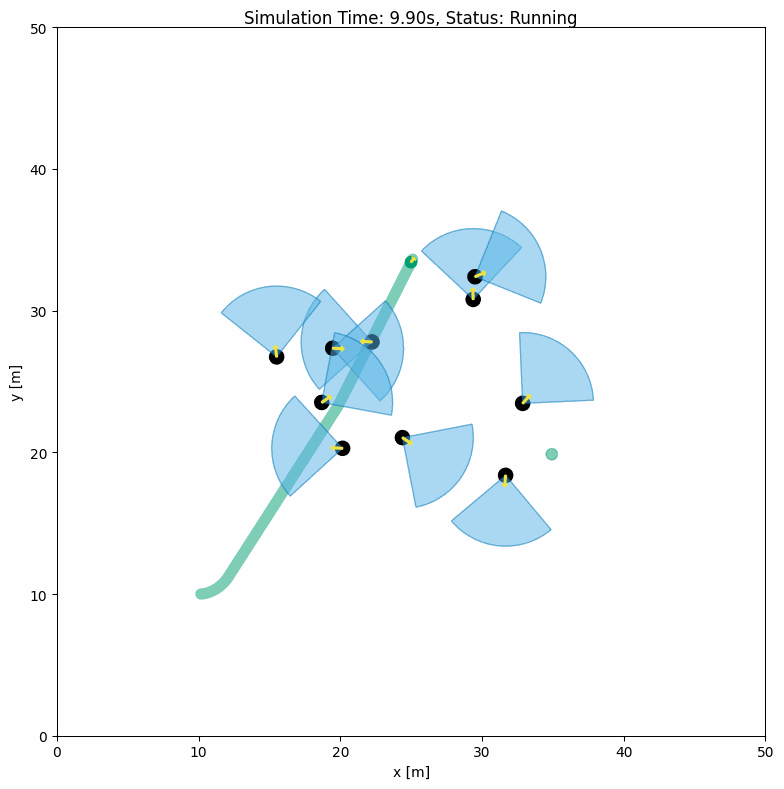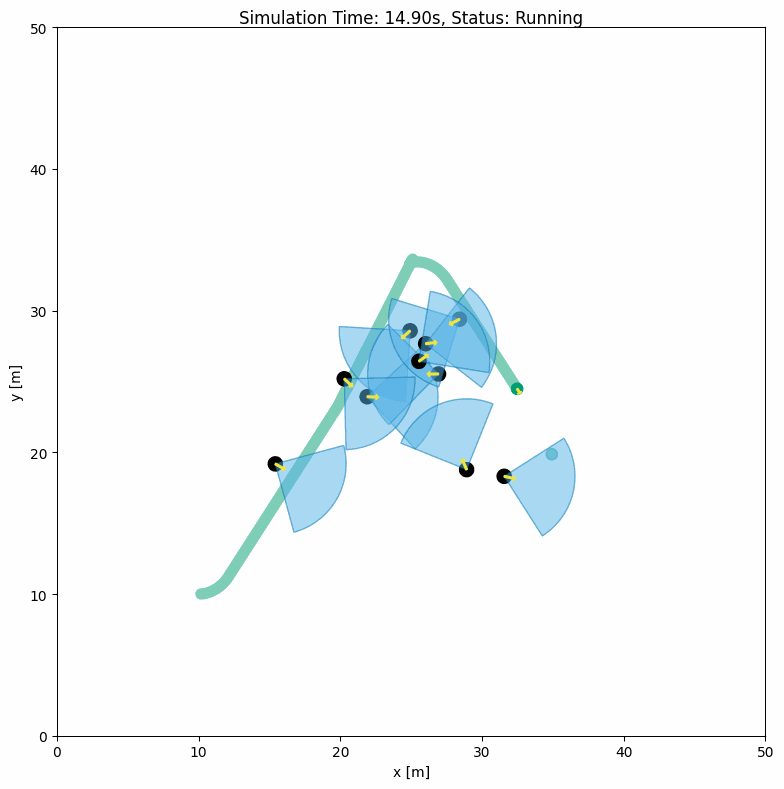 Field-of-View Detection Source |
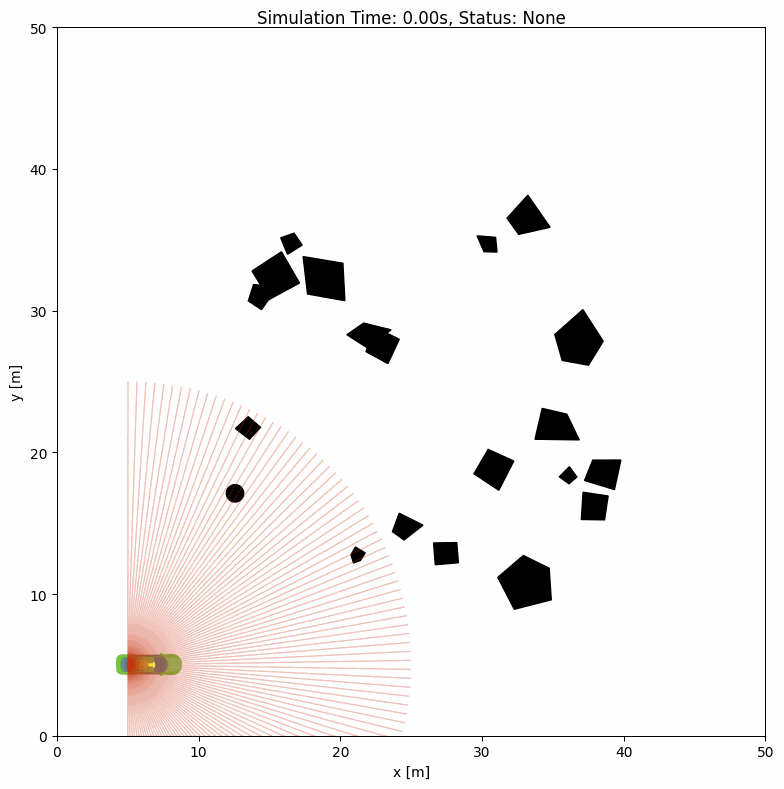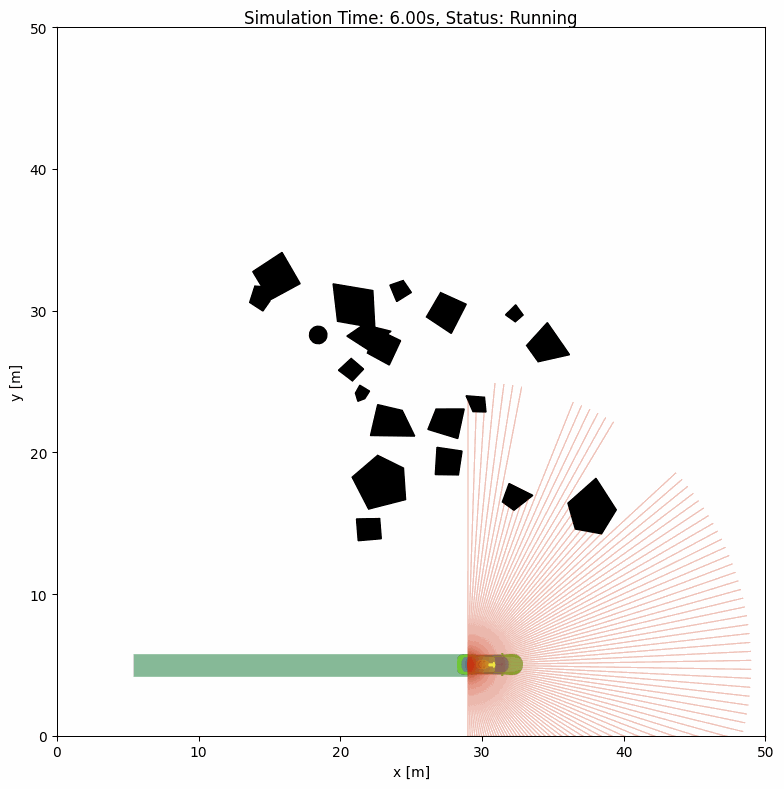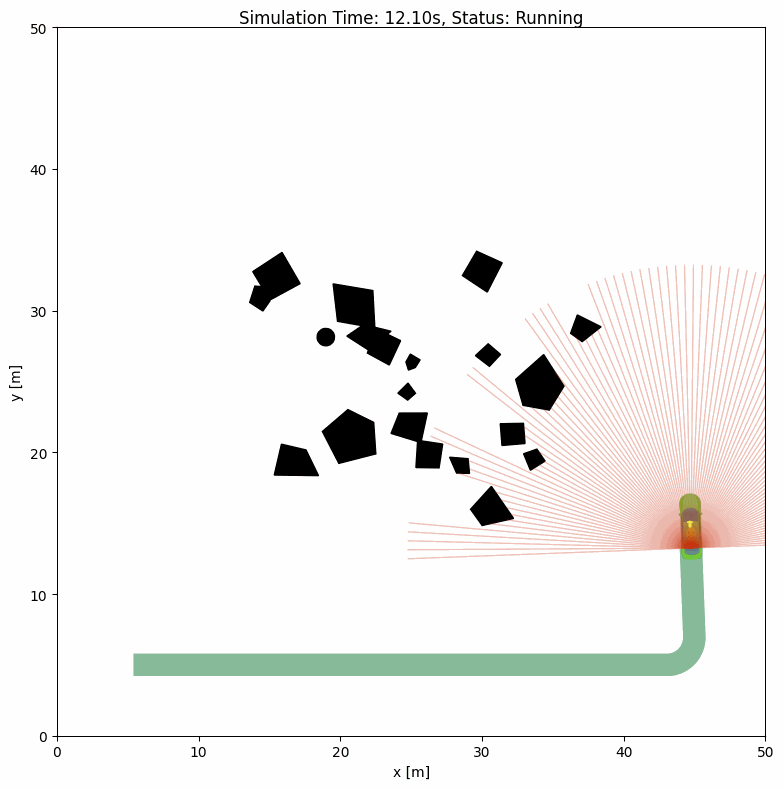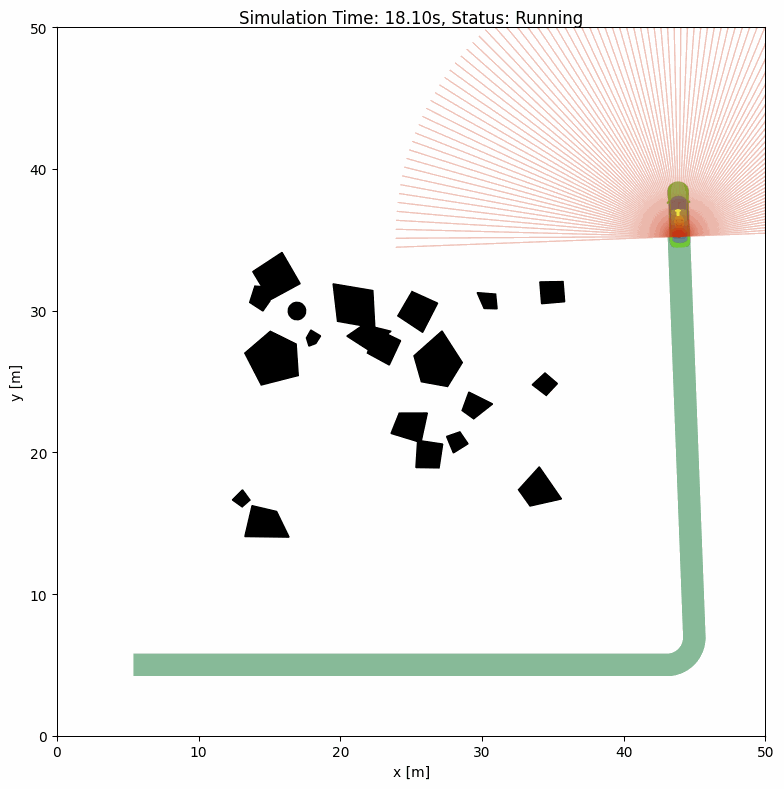 Dynamic Random Obstacles Source |
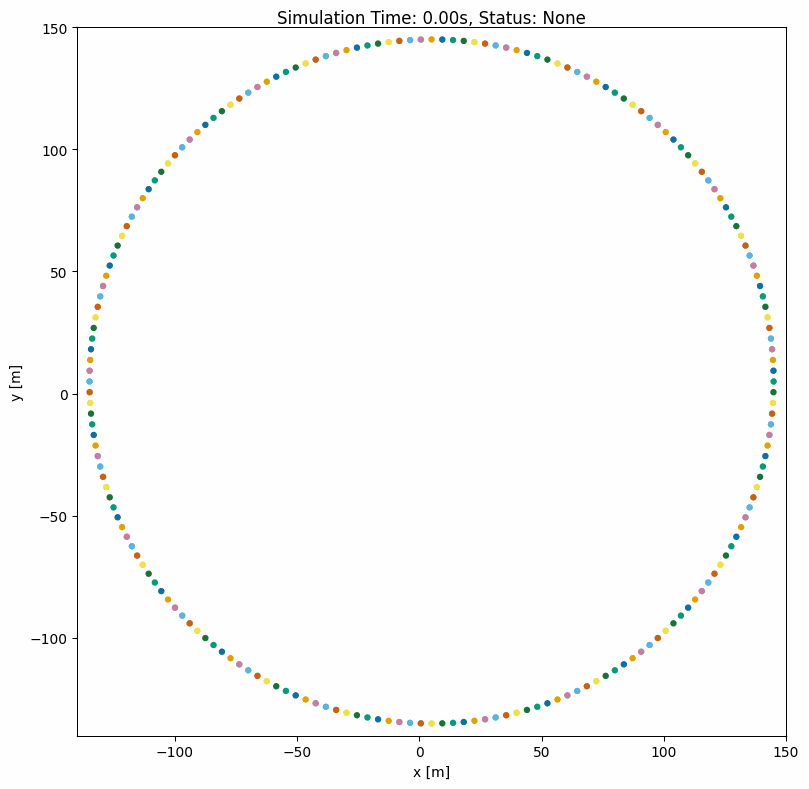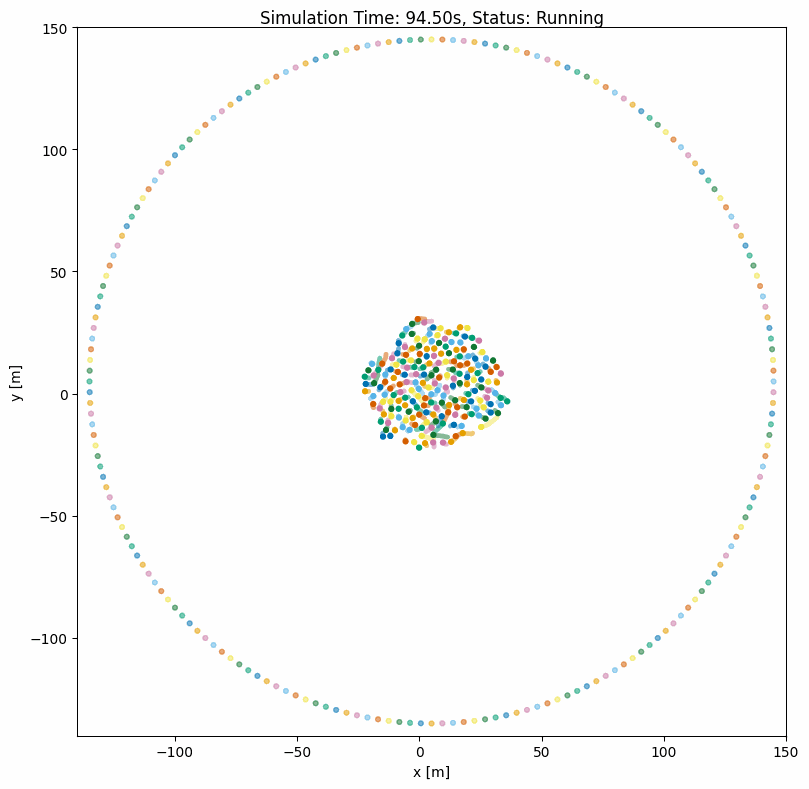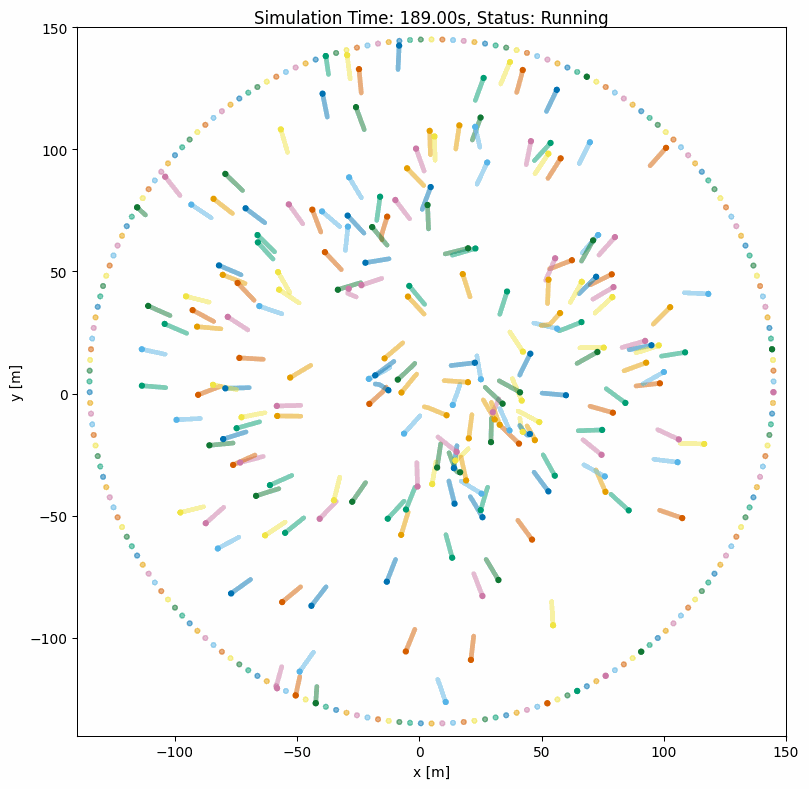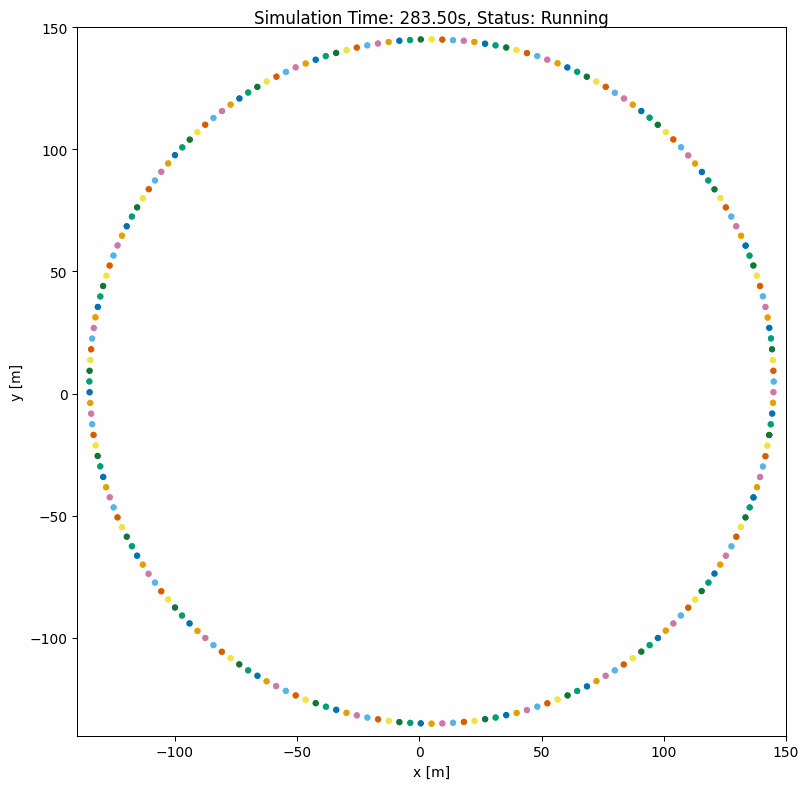 200-Agent ORCA via pyrvo Source |
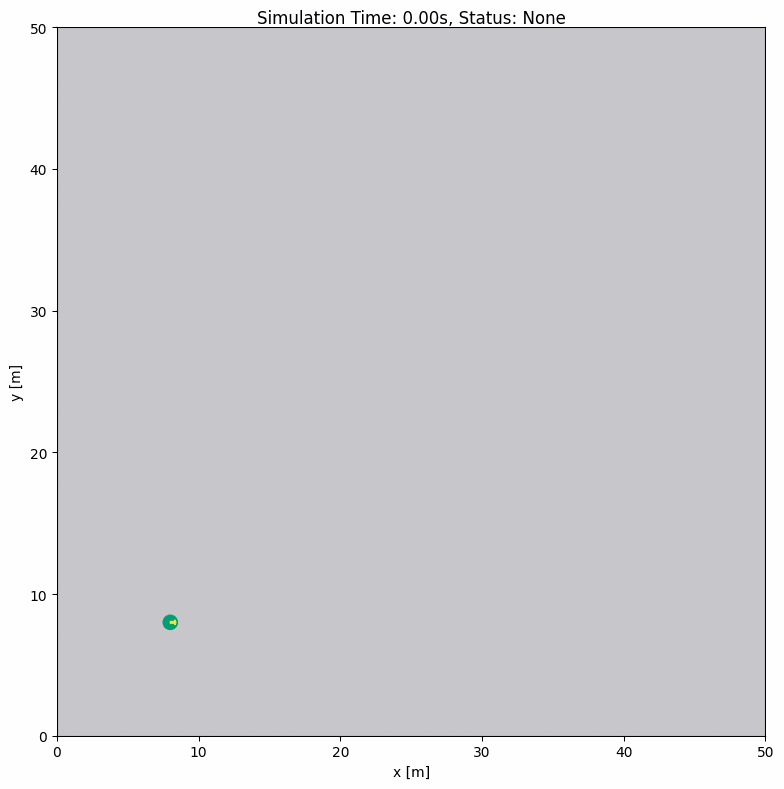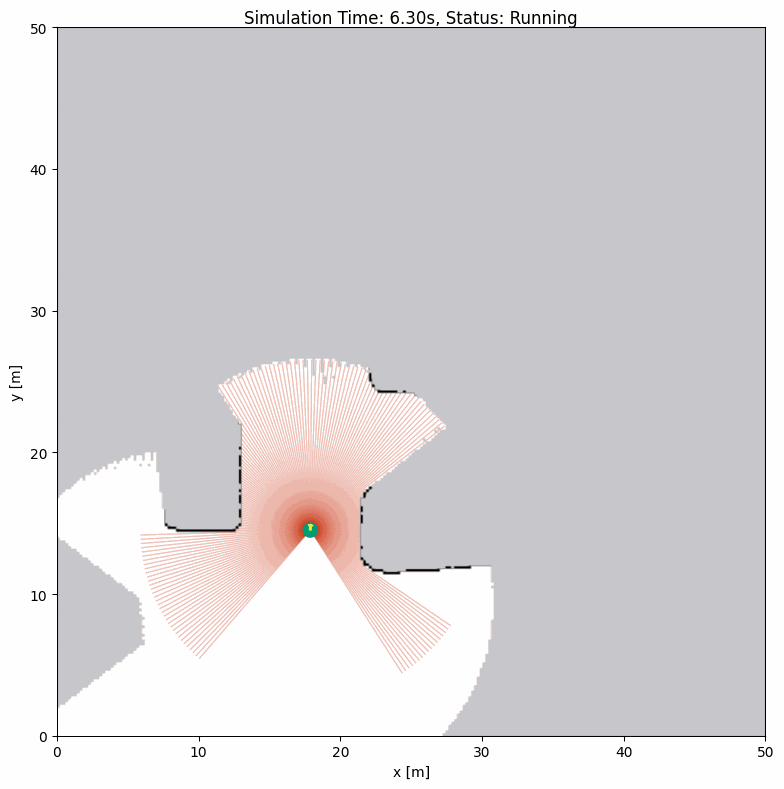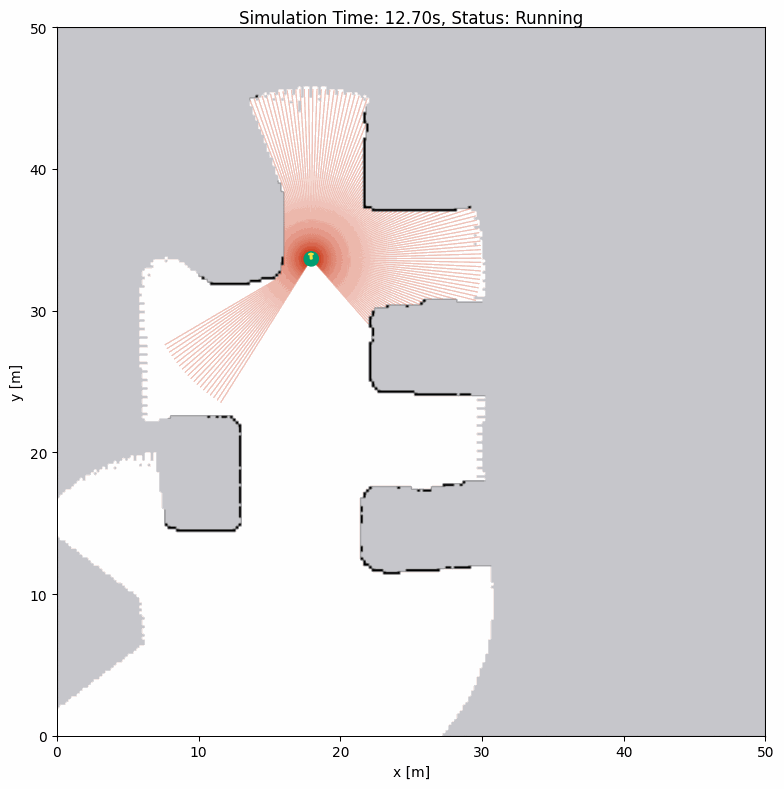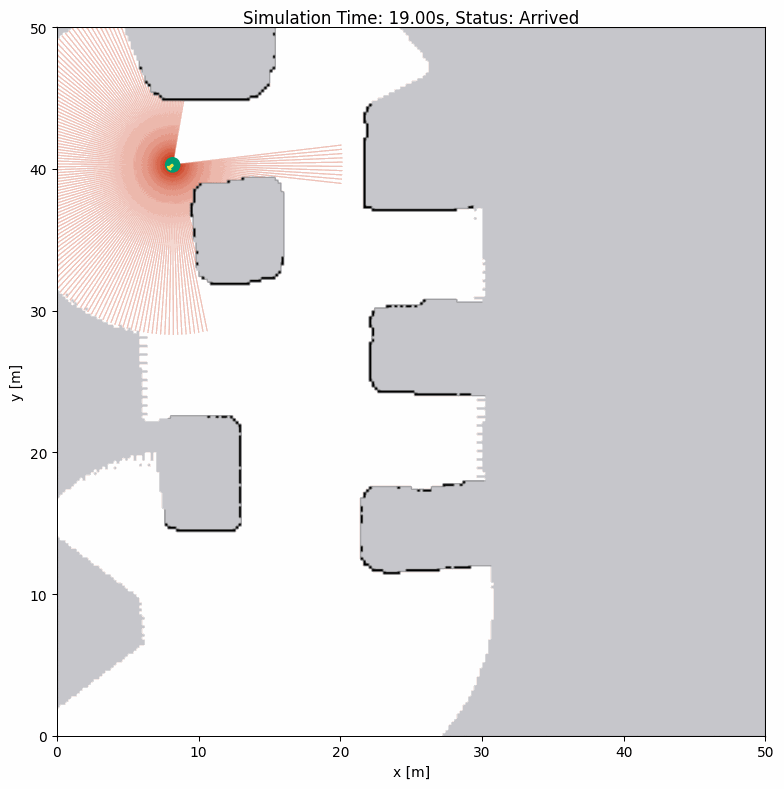 Fog-of-Map Exploration Source |
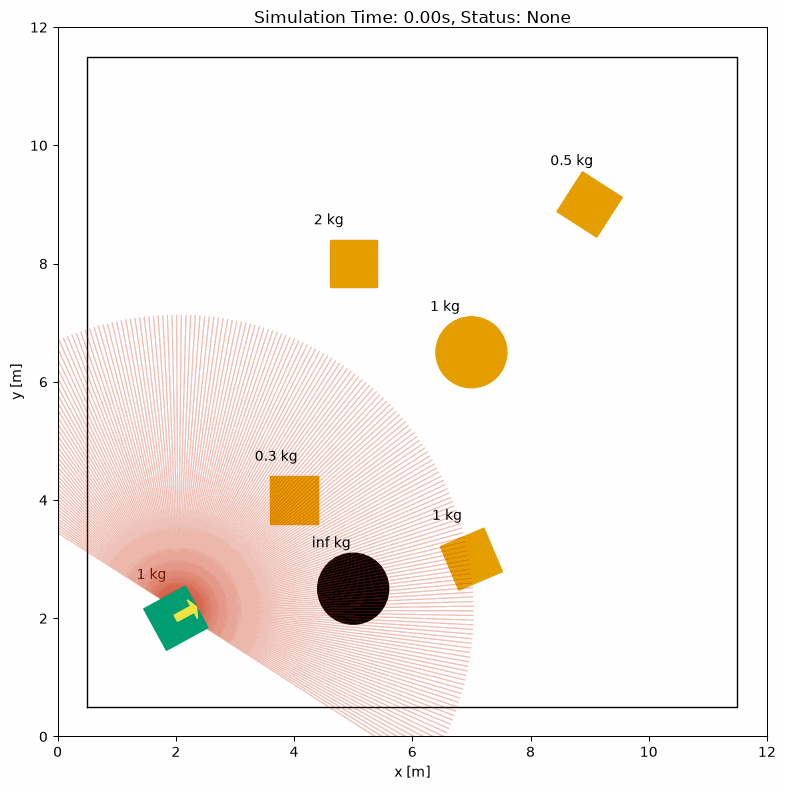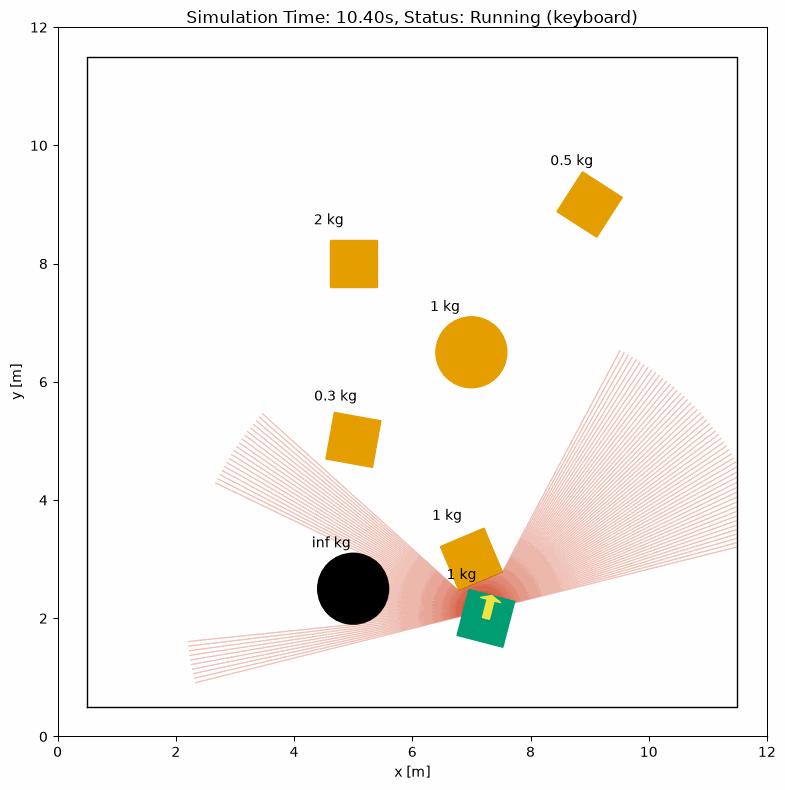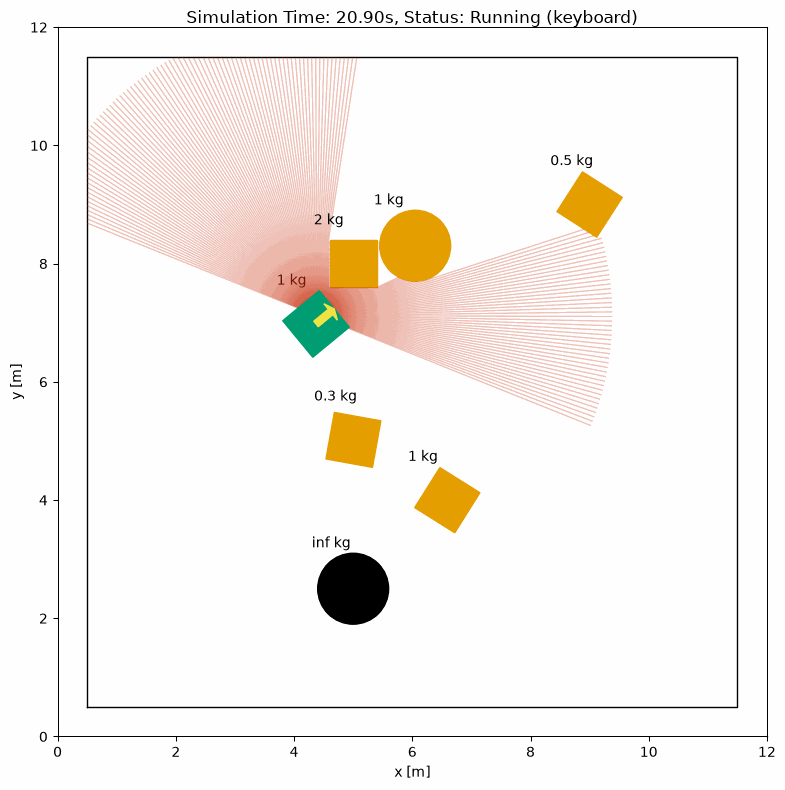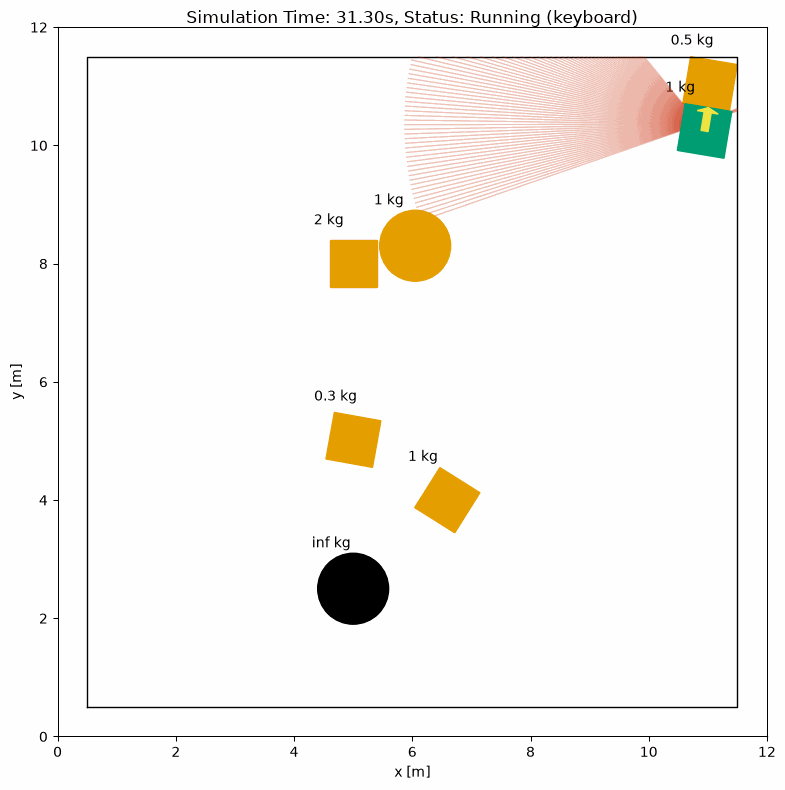 Rigid-Body Contact: Pushing Boxes Source |
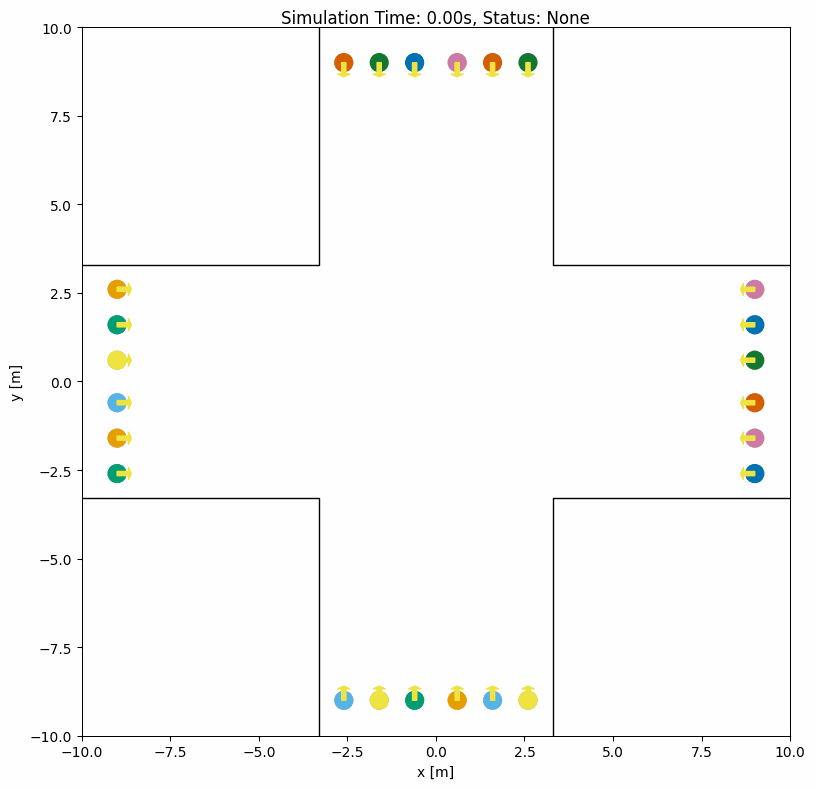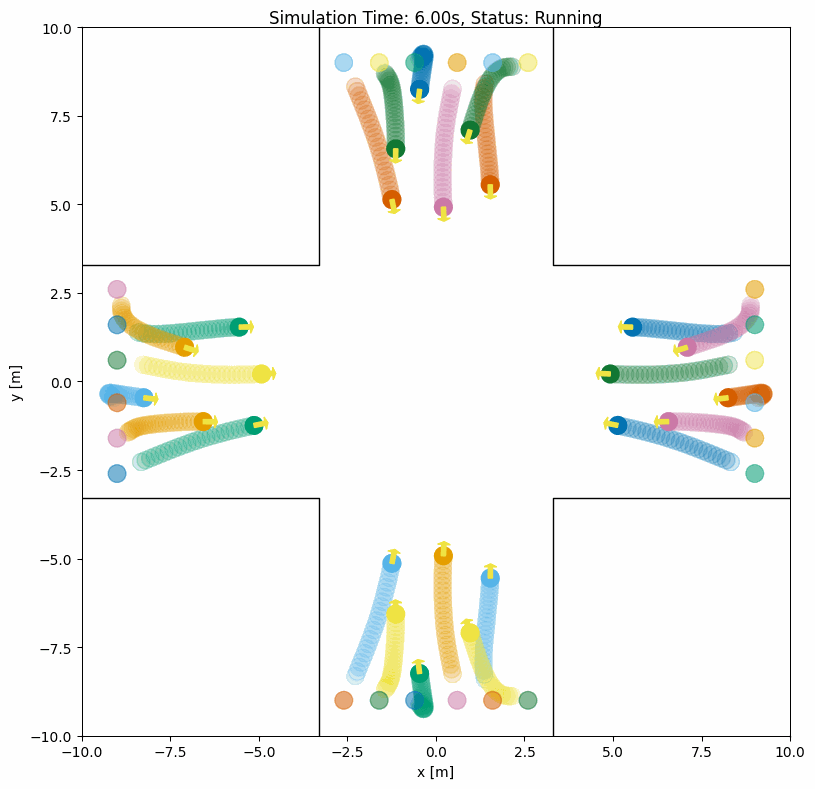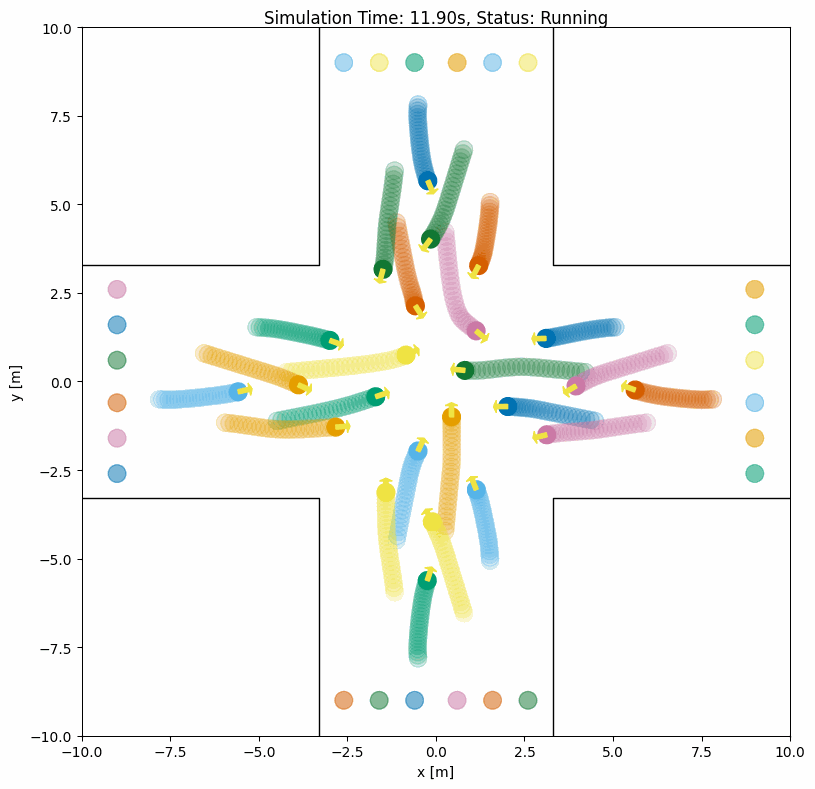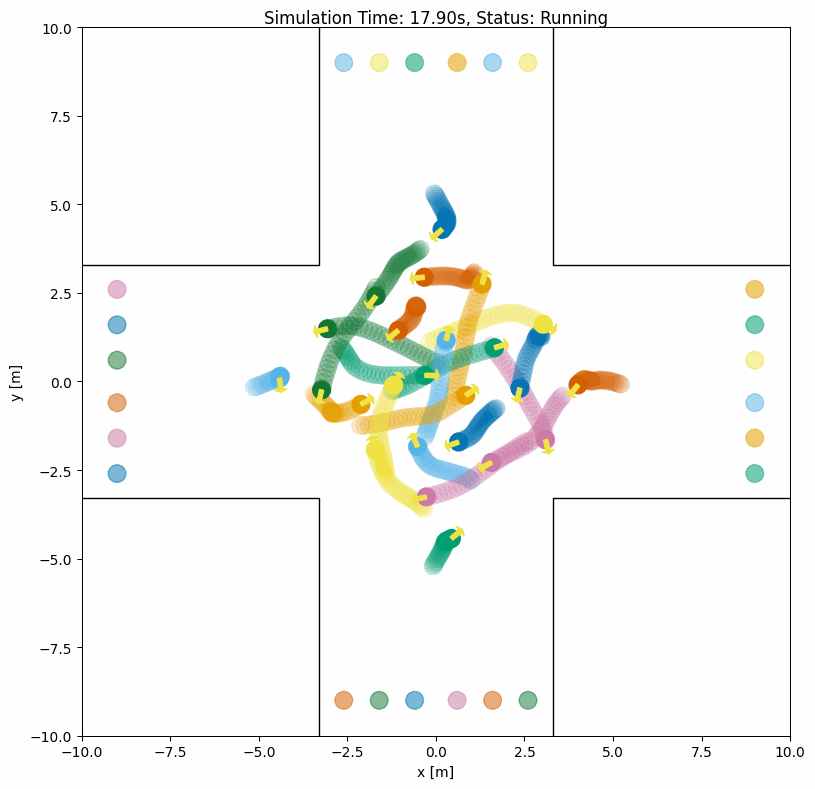 Social Force Model Pedestrians Source |
Requires Python >= 3.10
pip install ir-sim

# Optional: keyboard control and all extras
pip install ir-sim[all]git clone https://github.com/hanruihua/ir-sim.git
cd ir-sim
pip install -e .git clone https://github.com/hanruihua/ir-sim.git
cd ir-sim
uv syncA minimal example: a differential-drive robot navigates toward a goal using the built-in dash behavior.
import irsim

env = irsim.make(
    "robot_world.yaml"
)  # initialize the environment with the configuration file

for i in range(300):  # run the simulation for 300 steps
    env.step()  # update the environment
    env.render()  # render the environment

    if env.done():
        break  # check if the simulation is done

env.end()  # close the environment
YAML Configuration: robot_world.yaml
world:
  height: 10  # the height of the world
  width: 10   # the width of the world
  step_time: 0.1  # 10Hz calculate each step
  sample_time: 0.1  # 10 Hz for render and data extraction
  offset: [0, 0] # the offset of the world on x and y

robot:
  kinematics: {name: 'diff'}  # omni, omni_angular, diff, acker
  shape: {name: 'circle', radius: 0.2}  # radius
  state: [1, 1, 0]  # x, y, theta
  goal: [9, 9, 0]  # x, y, theta
  behavior: {name: 'dash'} # move toward to the goal directly
  color: 'g' # green
For more examples, see the usage directory and the documentation.
| Category | Features |
|---|---|
| Kinematics | Differential Drive mobile Robot · Omnidirectional mobile Robot · Omnidirectional with Angular control · Ackermann Steering mobile Robot |
| Sensors | 2D LiDAR · 2D FMCW LiDAR · Contact Sensor · FOV Detector |
| Geometries | Circle · Rectangle · Polygon · LineString · Binary Grid Map · Fog of Map |
| Behaviors | dash (move directly toward goal) · RVO (Reciprocal Velocity Obstacle) · ORCA (Optimal Reciprocal Collision Avoidance) · SFM (Social Force Model, per-object and group with social groups) |
| Collision | stop · unobstructed · unobstructed_obstacles · contact (rigid-body pushing with mass, friction and inertia: robots push what they can overcome, stall against heavier boxes, off-center pushes turn boxes, released boxes slide to a stop, walls block) |
- English: https://ir-sim.readthedocs.io/en
- Chinese (中文): https://ir-sim.readthedocs.io/zh-cn
- [RAL & ICRA 2023] rl-rvo-nav -- Reinforcement learning-based RVO behavior for multi-robot navigation.
- [RAL & IROS 2023] RDA_planner -- Accelerated collision-free motion planner for cluttered environments.
- [T-RO 2025] NeuPAN -- Direct point robot navigation with end-to-end model-based learning.
- [ROBIO 2025] MfNeuPAN -- Proactive end-to-end navigation in dynamic environments using direct multi-frame point constraints.
- [WCL 2025] Robotic Sensor Network: Achieving Mutual Communication Control Assistance With Fast Cross-Layer Optimization -- Cross-layer communication and control optimization evaluated on IR-SIM.
- [IROS 2026] SDLW -- Decentralized scalable exploration using sensor-driven Lévy walks for minimal-sensing robot teams.
- [Sensors 2026] PPO-GAT-Follow -- Graph-attention reinforcement learning for robot person following in dense crowds.
- [TWC 2026] Energy-Efficient Federated Edge Learning for Small-Scale Datasets in Large IoT Networks -- Energy-efficient federated edge learning evaluated through IR-SIM autonomous-navigation experiments and CARLA validation.
- DRL-robot-navigation-IR-SIM -- Deep reinforcement learning for robot navigation.
- AutoNavRL -- Autonomous navigation using reinforcement learning.
- IRSIM-3DGS-Bridge -- A closed-loop bridge from 3D Gaussian Splatting scenes to IR-SIM planning/following and back to Habitat-GS trajectory playback.
- EdgeVox -- Offline voice-agent framework with an IR-SIM mobile-navigation backend.
- The University of Hong Kong (HKU): COMP3356 Robotics
- Southern University of Science and Technology (SUSTech): CS401 Intelligent Robotics
If your publication, project, or course uses IR-SIM, we welcome proposals for inclusion via an issue or pull request.
If you find IR-SIM useful, please consider starring ⭐ this project and citing our paper:
@article{han2026ir,
  title={IR-SIM: A Lightweight Declarative Simulator for Navigation Learning and Benchmarking},
  author={Han, Ruihua and Wang, Shuai and Li, Chengyang and Gao, Rui and Wang, Xinyi and Liu, Zhe and Li, Guoliang and Lu, Yupu and Hao, Qi and Pan, Jia and Zhao, Hengshuang},
  journal={arXiv preprint arXiv:2606.08729},
  year={2026},
  doi={10.48550/arXiv.2606.08729},
  url={https://arxiv.org/abs/2606.08729},
  eprint={2606.08729},
  archivePrefix={arXiv},
  primaryClass={cs.RO}
}Contributions are welcome! Please see CONTRIBUTING.md for guidelines.
IR-SIM is released under the MIT License.